Communication
Edge networking
A second link gives the team a way to reach the robot if its usual network stops working

Doceva hardware
We’re building a separate way for teams to reach a robot when its main computer freezes or its network goes down
First prototype in development
System overview
A robot’s main link carries its everyday traffic
Our network gives the recovery module its own connection, so your team has another way in when the usual link fails
Fleet team
Hardware families
We design the network, the recovery module and the small computers that bring them together
Communication
A second link gives the team a way to reach the robot if its usual network stops working
Recovery
A controller with its own backup power stays on the robot so the team can check its main computer
Onboard computing
A whole computer on one circuit board, designed for our recovery hardware
Recovery process
A lost connection and a frozen computer can look the same from the site office
The recovery module checks whether the main computer is still answering
The team uses the separate link to check what went wrong before deciding on a restart
If a restart is enough, the team can do it without sending someone to the site
Design limits
The lifeline never goes around the robot’s own safety controls
Broken parts and robots that tip over still need someone on site
Applications
We’re designing the lifeline for small robotics teams whose fleets work far from a technician
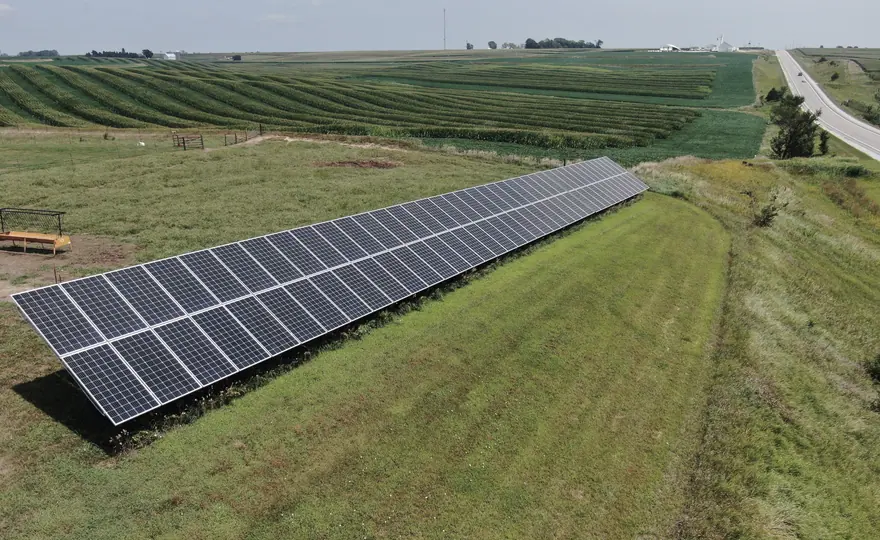
Robots work across wide fields of panels, far from the site office
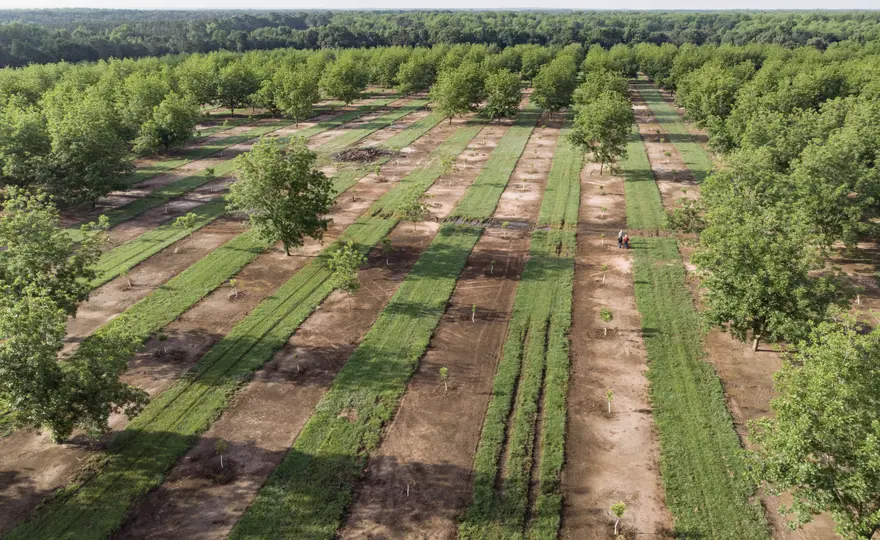
Farm robots spread out over large fields, a long way from the nearest technician
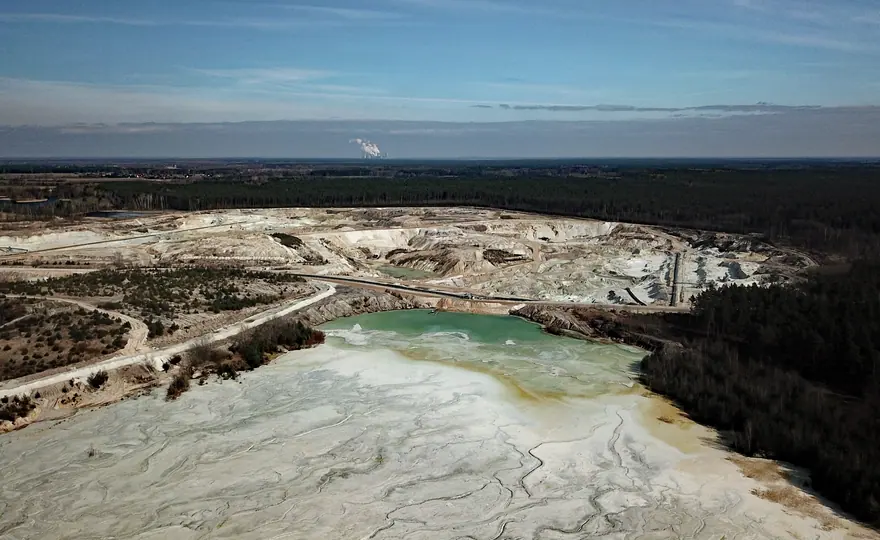
Mine sites are remote and slow to reach, so every trip takes a person off other work
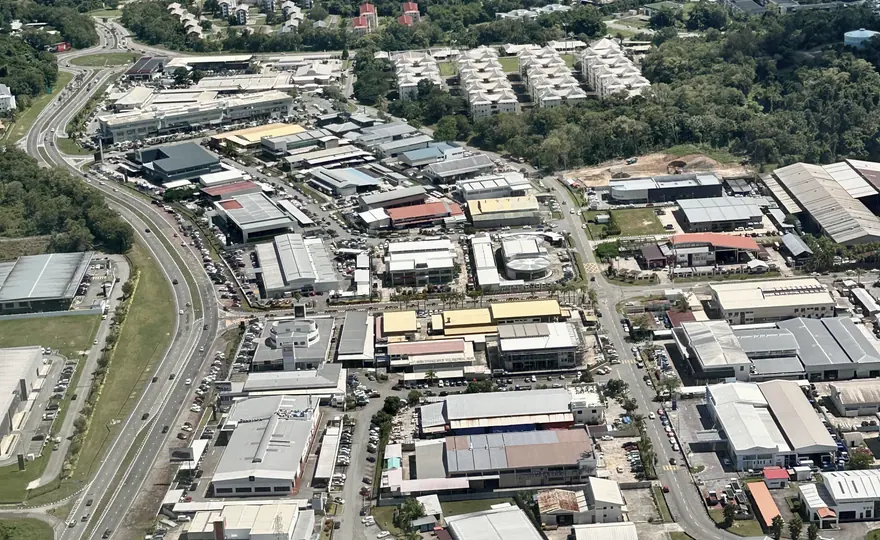
Large facilities run robots in places that take time to get to
Development status
The circuit drawings are ready and we’re sourcing parts for the first prototype
Our hardware is not for sale yet
See our progress